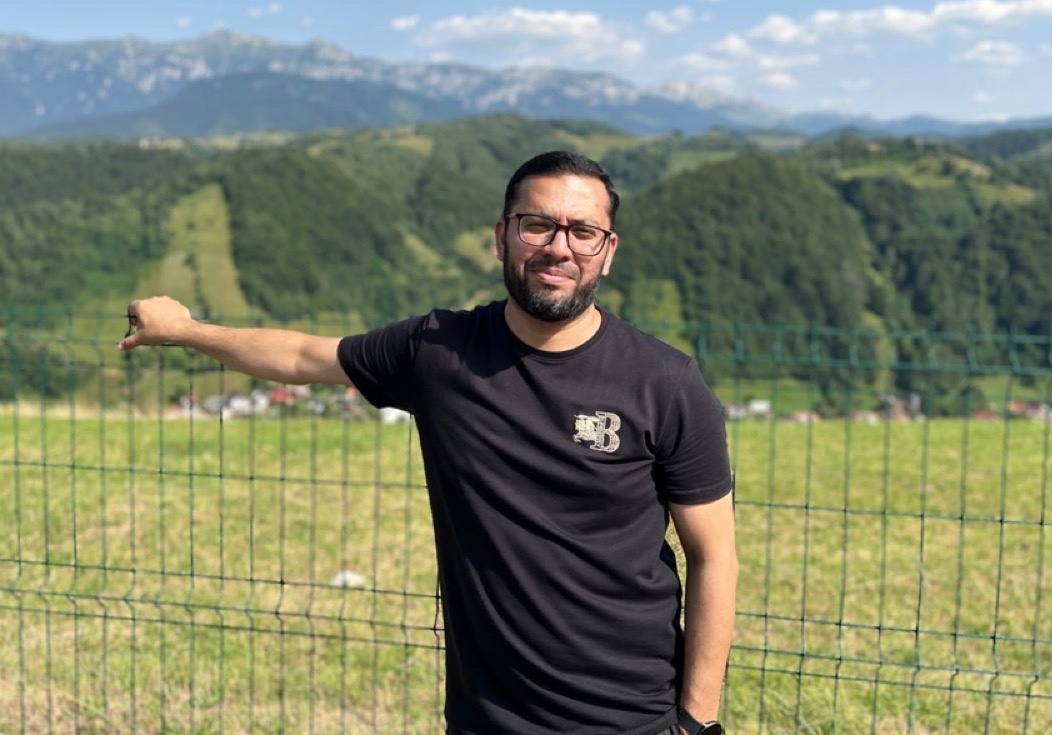
Usman Qayyum

AI Product Builder — from autonomous systems to agentic swarms.

Founder & CTO at AI Resolve. Gold medalist, award-winning inventor, and educator — 20+ years in AI, robotics, and computer vision.

Usman Qayyum outdoors in the Carpathian mountains, Romania

Profile

About

Dr. Usman Qayyum is a researcher, AI practitioner, and roboticist with 20+ years in the field. He earned his MS from NUST as a gold medalist (2006) and a PhD in Robotics and Artificial Intelligence from the Australian National University (2014), focused on autonomous aerial vehicles.

His postdoctoral work on self-driving cars at A*STAR earned a USD 15,000 prize; in July 2015 he demonstrated Singapore’s first self-driving car to Prime Minister Lee Hsien Loong. He has contributed 35+ papers, authored a computer-vision book, supervised BE/MS/PhD research, and served on the evaluation board for research funding at the National Center of Artificial Intelligence (NCAI).

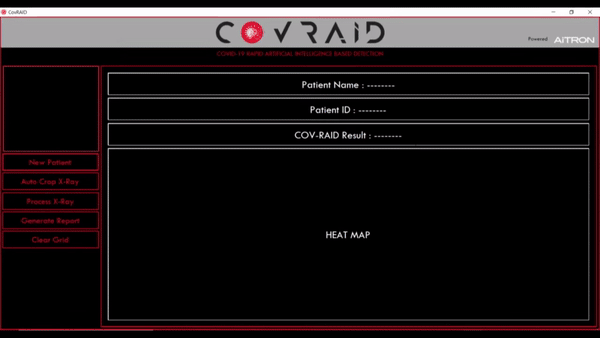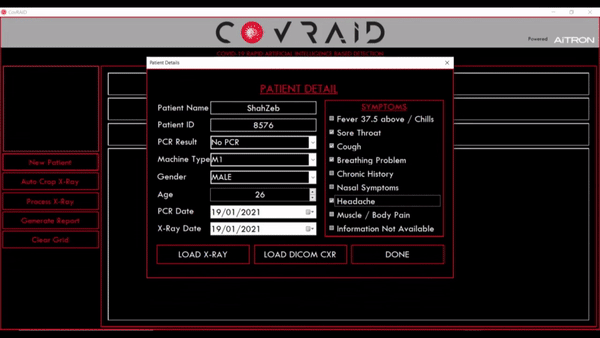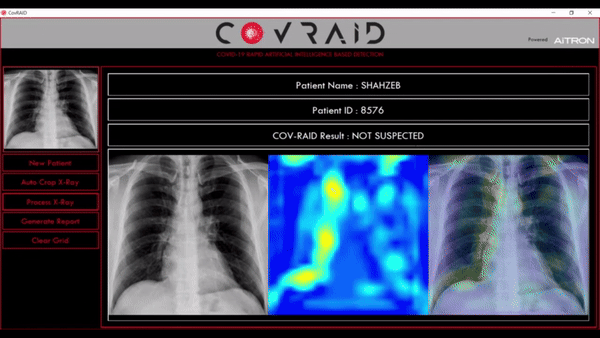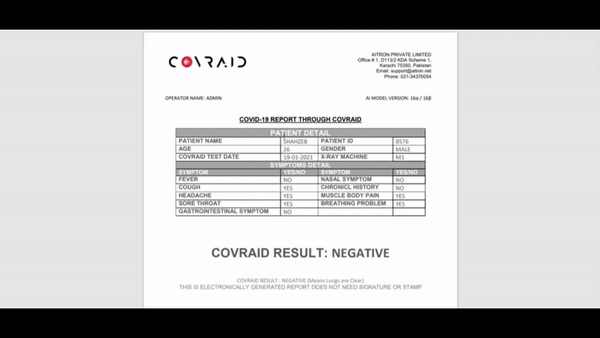
He led Pakistan’s first PEC- and DRAP-approved electro-medical AI device and a team that won the PASHA ICT award in AI healthcare — with deep experience across AI, deep learning, robotics, computer vision, predictive analytics, and healthcare.

Recognition

Selected achievements

  • PASHA Software House / ICT Award — AI for Healthcare
  • Pakistan’s Achievement Medal — 2022
  • DRAP-approved AI COVID-19 product — AI Healthcare, 2021
  • PEC-recognized inventor — First Pakistani Electro-Medical AI Device, 2021
  • First Self-driving Car Demonstration — to Prime Minister of Singapore, July 2015
  • PostDoc prize — USD 15,000, 2015
  • President Gold Medal · Gold Medal — MS (CSE), 2006
  • Silver Medal — BE (CSE), 2004
  • 2nd place for Followme Robot — All-Pakistan GIKI SOFTCOM software competition, 2003
  • Scholarship — BESE / MS / PhD studies

AI Resolve · Product portfolio

AI products

Live, demoable systems across agentic workflows, LLMs, RPA, and computer vision — validated with real clients and deployments.

Agentic Workflows Large Language Models Autonomous Systems Computer Vision

Core product

ComplyTrade

AI-based LC compliance

Automates international trade documentation for SWIFT Category 7 compliance. Ingests LC SWIFT messages (MT700, MT701, MT707, MT799), then consolidates, classifies, and verifies documents against credit terms — with discrepancy detection, audit trails, and compliance reporting.

Validated through procurement with various Pakistan's Banks.
Platform

Nexus

Autonomous recruitment

Agent-driven, voice-based interview platform that designs, conducts, and evaluates candidate interviews. Multi-agent architecture with MCP-powered sentiment analysis, real-time voice interaction, and an instant Hire/Reject scorecard with full transcript.

Deployed at Corporate Level.

Deployment

DigiArchive

Intelligent search & workflow

Intelligence layer over scanned bank and institutional archives: AI indexing, signature verification, semantic search, and automated routing — closing the digitization gap with audit trails and anomaly detection.

Pilot with the Senate of Pakistan.

Computer vision

AI Analytics Engine

Face & vehicle recognition

Real-time Vehicle detection, recognition, and activity tracking across live video streams — with alerts and authorized actions for access control and public safety.

Deployed and Tested in the Safe City Islamabad.

Research · A*STAR

Self-driving car

Autonomous vehicle demonstration

Postdoctoral work on self-driving cars at A*STAR, Singapore — including the demonstration of Singapore’s first self-driving car to Prime Minister Lee Hsien Loong in July 2015.

Customer support

Wizbot

WhatsApp AI chatbot

RAG-powered WhatsApp assistant trained on business data — answering enquiries, qualifying leads, and booking appointments around the clock via WhatsApp Business.

Fintech

AssetTokenizerApp

Tokenized asset marketplace

AssetTokenizerApp isn’t just a trading platform — it’s the foundation for a more inclusive financial future. By breaking down massive assets into accessible tokens, it gives average investors unprecedented portfolio diversification and gives asset owners a highly liquid, global market for their instruments.

Security screening

AI-enabled XBS

X-ray baggage scanner

X-ray baggage scanner with integrated artificial intelligence for detection and localization of prohibited objects — supporting faster, more reliable security screening.

Research & vision demos

Selected robotics and computer-vision systems — from aerial SLAM to multi-object tracking.

Multi-object detector & tracker

Occlusion handling from a commercial DJI quadcopter.

Self-driving localization & control

Velodyne / IMU / encoder fusion for localization and control.

Visual-inertial SLAM for MAVs

MAV navigation in cluttered outdoor environments.

Bowler tracking & pose estimation

Sports vision: tracking and pose estimation for bowling.

Object detector & tracker

General-purpose object detection and tracking pipeline.

SWARM demo

Leader–follower formation for autonomous multi-robot swarming.

Earlier & adjacent products

Histopathology Cancer Detection

Cancer screening from histopathology imagery.

Swarm Intelligence

Autonomous UAV/UGV navigation.

Intelligent Pulse Oximeter

Android-controlled analytics and patient alarms.

Edge computing

Face & emotion recognition on Intel Movidius.

ECG device

Low-cost AI detection of AF, bradycardia, tachycardia.

Speech

Urdu/local ASR and English & Urdu speech synthesis.

OSINT

Social media monitoring for fake news and sentiment.

Home automation

IoT lighting, fans, and ACs via Android.

Cybersecurity

Mobile vulnerability analysis and patching.

Genomics

Genomics-based cancer detection.

Experience

Career

  1. Founder & Chief Technology Officer

    AI Resolve

  2. Track Lead & Program Coordinator — AI & Software Technologies

    IEEE IBCAST conference · Islamabad

  3. Board Member

    National Center of Artificial Intelligence (NCAI), Pakistan

  4. Director AI

    Center of Excellence

  5. Research Engineer

    Pi School, Italy

  6. Research Scientist — Self-driving cars

    A*STAR, Singapore

  7. Teaching Assistant / Robotics Lecturer

    Australian National University

  8. Computer Vision Scientist

    Computer Vision Center, Barcelona

  9. Computer Vision Engineer

    Center of Excellence

Education

  • PhD — Australian National University, 2010–2014
    Thesis: Visual-Inertial intelligent SLAM for Small Scale Aerial Vehicles
  • Designing and Building AI Products and Services — Massachusetts Institute of Technology, 2024
  • MS (Computer Vision / Software Engineering) — NUST, 2004–2006 · Gold Medal
    Thesis: Real-time Notch based Face Detection, Tracking and Facial Feature Localization
  • BESE — National University, 2000–2004 · Silver Medal
    Thesis: Vision for Safe Driving on Motorway

Speaking

Invited talks & seminars

  • Beyond LLM: Swarm Intelligence and decentralized agentic orchestration

    AI Foundations & Frontiers for the Future Spring School — LUMS, 2026

  • AI theory and agentic reality

    Software House Association, 2026

  • AI for Particle Physics: Tracking and Classification via Accelerator Chip

    8th IWTD — National Centre for Physics, 2026

  • Agentic AI Systems

    DPL’s AI Hackathon Training, 2026

  • Quantum Machine Learning

    NUST Lecture Hall, 2025

  • AI Agents: The Next Revolution

    Software House Association, 2025

  • LLM for Vulnerability Pattern Detection

    IEEE C-Code — Bahria University, 2025

  • AI Agentic Systems and their workflows in CREWAI

    ICRAI, 2024

  • AI for cyber security: Practical Solutions or Hype

    Cyber Threat Intelligence Conference, 2024

  • How AI Accelerators Drive Performance & Efficiency

    IEEE SPS Seasonal School SIP4UAVs, 2024

  • Artificial intelligence fusion in education Industry

    Institute of Space Technology, 2024 · ivision

  • Artificial intelligence Operations for Smart City

    SLS & OPTIROB, Romania, 2024 · keynote

  • AI Practical Workshop using Gradio and Huggingface

    Engaging AI applications, 2024

  • MLOps: Journey of Deployment of AI applications

    SLS & OPTIROB, Romania, 2023

  • AI productization for Smart City

    20th IEEE IBCAST, 2023

Earlier talks available on request.

Research

Publications

Selected work across visual-inertial SLAM, autonomous driving, medical AI, and computer vision — ICRA, IROS, Sensors, and IEEE venues.

  1. S Shao, S Xie, Z Jin, Z Tan, H Wang, U Qayyum. Object Detection under Dynamic Environment with Application in Visual SLAM. 43rd Chinese Control Conference (CCC), 2024.
  2. Usman Qayyum, Sajid Baloch. Covid-19 Rapid Artificial Intelligence based Detection. Patent, 2021.
  3. Usman Qayyum, Jonghyuk Kim. Depth-Camera-Aided Inertial Navigation Utilizing Directional Constraints. Sensors 21(17): 5913, 2021.
  4. Usman Q, et al. End-to-end brightness correction in x-ray images to detect covid-19. IEEE IBCAST, 2020.
  5. Sajid Baloch, Usman Q, et al. COVRAID for COVID-19 Detection. IEEE IBCAST, 2020.
  6. M Raza, Usman Q. Classical and Deep Learning Classifiers for Anomaly Detection. IEEE IBCAST, 2019.
  7. Kamran C, M Babar, M Qadri, Usman Q. A High Speed and Resource Efficient Approximation of Softmax Loss Function. IEEE IBCAST, 2019.
  8. S Ullah, Usman Q, AJ Choudhry. Time and Memory Efficient 3D Point Cloud Classification. IEEE IBCAST, 2019.
  9. Usman Q, Qaisar A, Zahid M. Thermal Colorization using deep neural network. IEEE IBCAST, 2017.
  10. Usman Q, Qaisar A, Zahid M. IMU aided RGB-D SLAM. IEEE IBCAST, 2016.
  11. Sai M, Usman Q, Liu B. Sparse Depth Odometry: 3D Keypoint based pose estimation from dense depth data. ICRA, 2015.
  12. Weiwei H, Usman Q, Xiaoli M, Ning W. Autonomous Driving with multi-constraints fault detection and DDP based motion planner. IROS Workshop on Autonomous Vehicle, 2015.
  13. Xiaoli M, Usman Q, Liu B. Online URTS Smoother for 6DOF Vehicle Localization. ICARCV, 2014.
  14. U. Qayyum, J. Kim. Global Optimization for 2D SLAM Problem. LNEE Vol. 283, pp. 35–49, 2014.
  15. Usman Q & Kim. Inertial-Kinect Fusion for Outdoor 3D Navigation. ACRA, 2013.
  16. U. Qayyum, J. Kim. Consistency based calibration approach for visual-laser scanner. IEEE ROBIO, 2013.
  17. Usman Q & Kim. Real-time 6DOF Aerial SLAM with 2D-3D Visual Features. Journal of Field Robotics, 2013.
  18. Usman Q & Kim. Graceful Degradation of IMU-Kinect Fusion for Outdoor Aerial Navigation and Mapping.
  19. Usman Q & Kim. Analysis on the Number of Local Minima for Inertial-SLAM Problem. IEEE ROBIO, 2013.
  20. Usman Q & Kim. Omni-VISER: 3D Omni Vision-Laser Scanner. ACRA, 2012.
  21. Usman Q & Kim. Seamless Aiding of Inertial-SLAM using Visual Directional Constraints from a Monocular Vision. IROS, 2012.
  22. Usman Q & Kim. Global Optimal Solution to SLAM problem for unknown initial estimates. ICINCO, 2012 (12% acceptance; nominated for best paper).
  23. Usman Q & Kim. Visual-Odometry Integrated Inertial-SLAM. IGNSS, 2012.
  24. Usman Q. A real-time Approach to Face Detection and tracking. Book, Lambert, 2011.
  25. Usman Q & Kim. Accelerometer aided Visual Priors for Robust Monocular SLAM. TAROS, 2011.
  26. Usman Q & Qaisar A. Visual correspondence based trajectory estimation. IEEE IBCAST, 2010.
  27. Imran H, Qaisar A, Usman Q. Ensemble ANN with SVM for reducing false positive in Face Detection. IEEE IBCAST, 2010.
  28. Usman Q. Phase Efficient Neural Network Using Curve Features for Face Recognition. IEEE INMIC, 2008.
  29. Usman Q. Efficiency Enhancement of Neural Network with Phase Only Correlation. JDCTA, 2008.
  30. Usman Q. Face Detection and Facial Feature Localization Using Notch Based Templates. Journal of Engineering & Applied Sciences, 2008.
  31. Usman Q, Qaisar Ahsan, Javed M.Y. Fusion of Neural Network and Phase Only Correlation for Face Recognition. 2007.
  32. Jahan Z, Javed M.Y., Usman Q. Low Resolution Single Neural Network Based Face Recognition. International Journal of Biomedical Sciences, 2007.
  33. Azhar I, Javed M.Y., Usman Q. Curvelet Based Image Compression. IEEE ICCIT, South Korea, 2007.
  34. Akhlaq A, Javed M.Y., Usman Q. A Robust Fuzzy Logic Based Approach for Skin Detection in Colored Images. ASC, Spain, 2007.
  35. Jahan Z, Javed M.Y., Usman Q. Low Resolution Single Neural Network Based Face Recognition. CISP, Czech Republic, 2007.
  36. Usman Q, Javed M.Y. Lane Change Detection Using Fusion of IPM and SVM. ISC, Cambridge MA, 2005.

Connect

Let’s build something that ships.

Open to collaborations in agentic AI, computer vision, robotics, and production ML systems.